Pro & Industrial Edition Features
Advanced static code analysis, logic visualization, industrial safety compliance, and fleet maintenance suite.
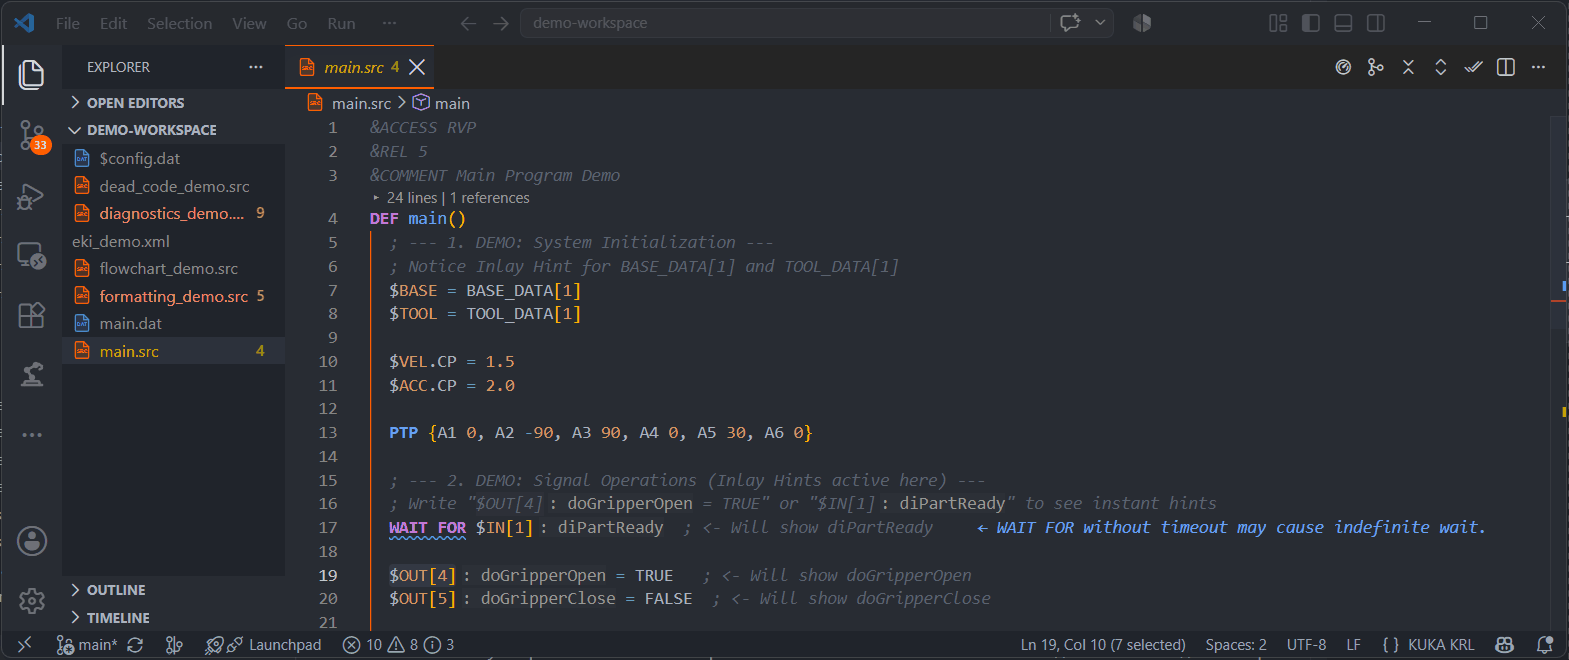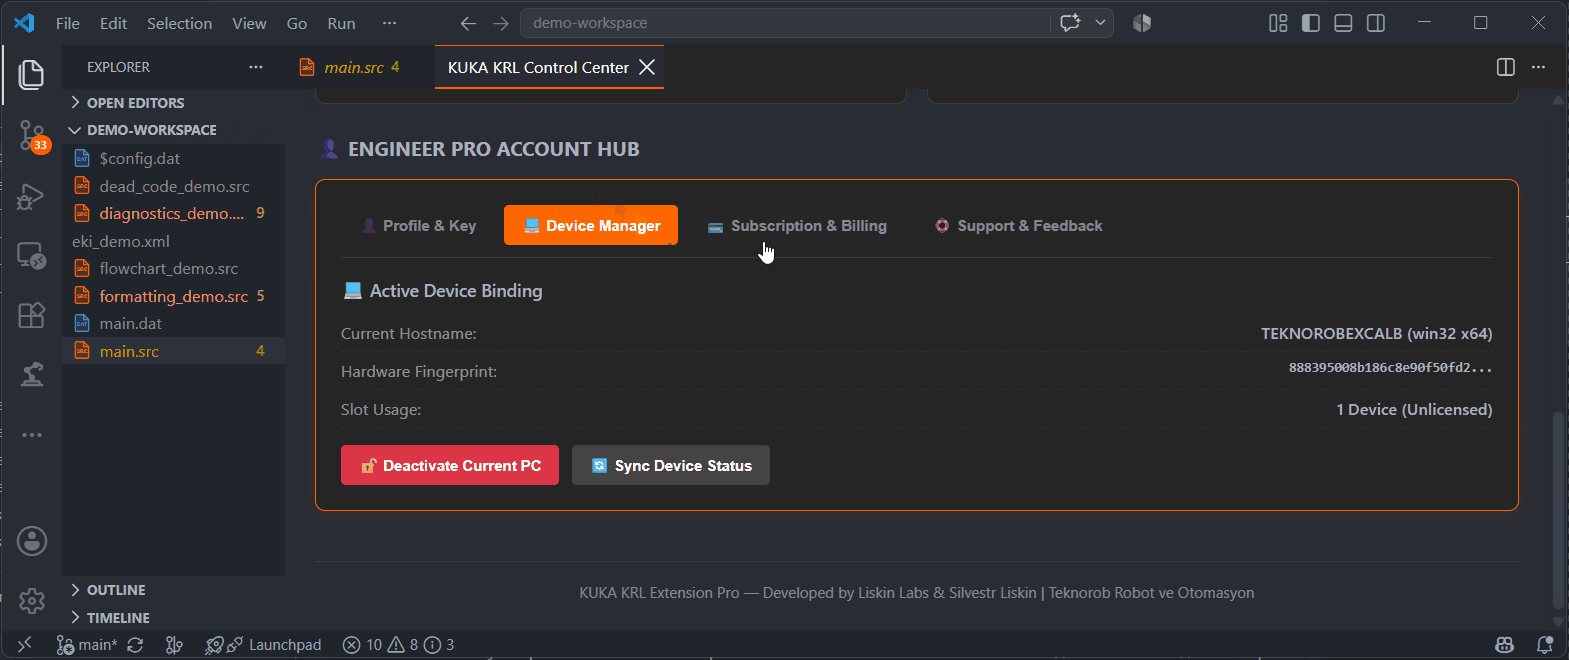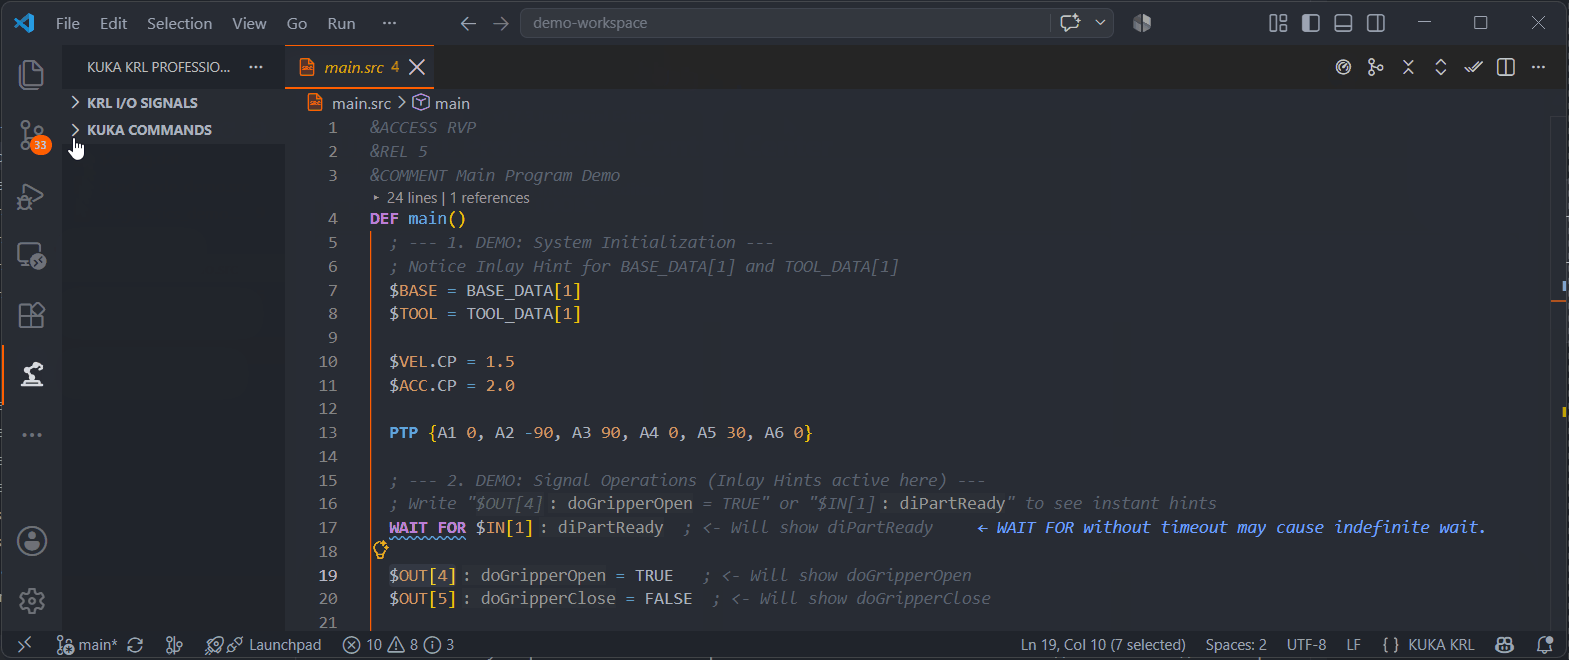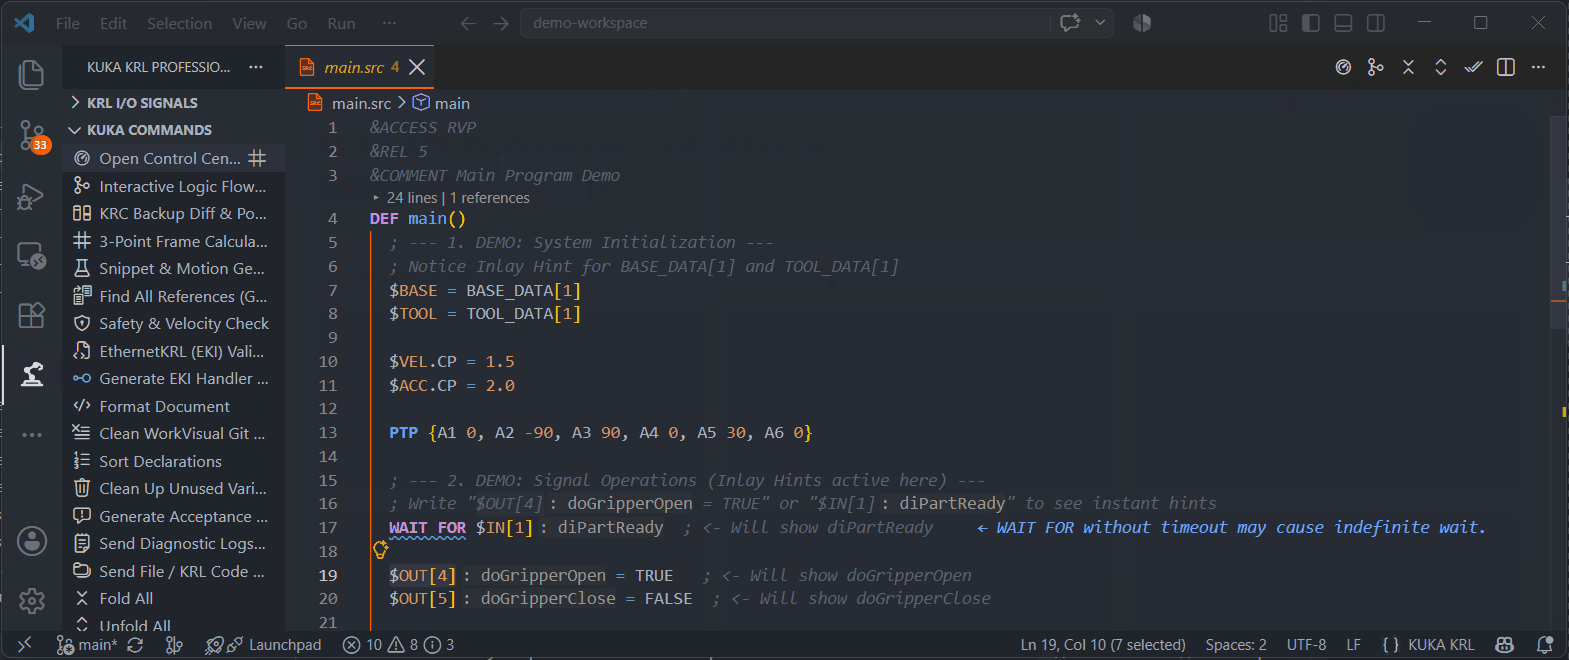
16. KUKA Control Center Dashboard (krl.openControlCenter)
Fluent UI command center providing 1-click access to all Pro diagnostics, backup analytics, trajectory builders, and licensing.
17. VS Code Telegram Support Chat Panel (krl.openTelegramChat)
Embedded support chat window directly inside the IDE connected with our dedicated Telegram Support Gateway for real-time engineering feedback and bug reports from the shop floor.
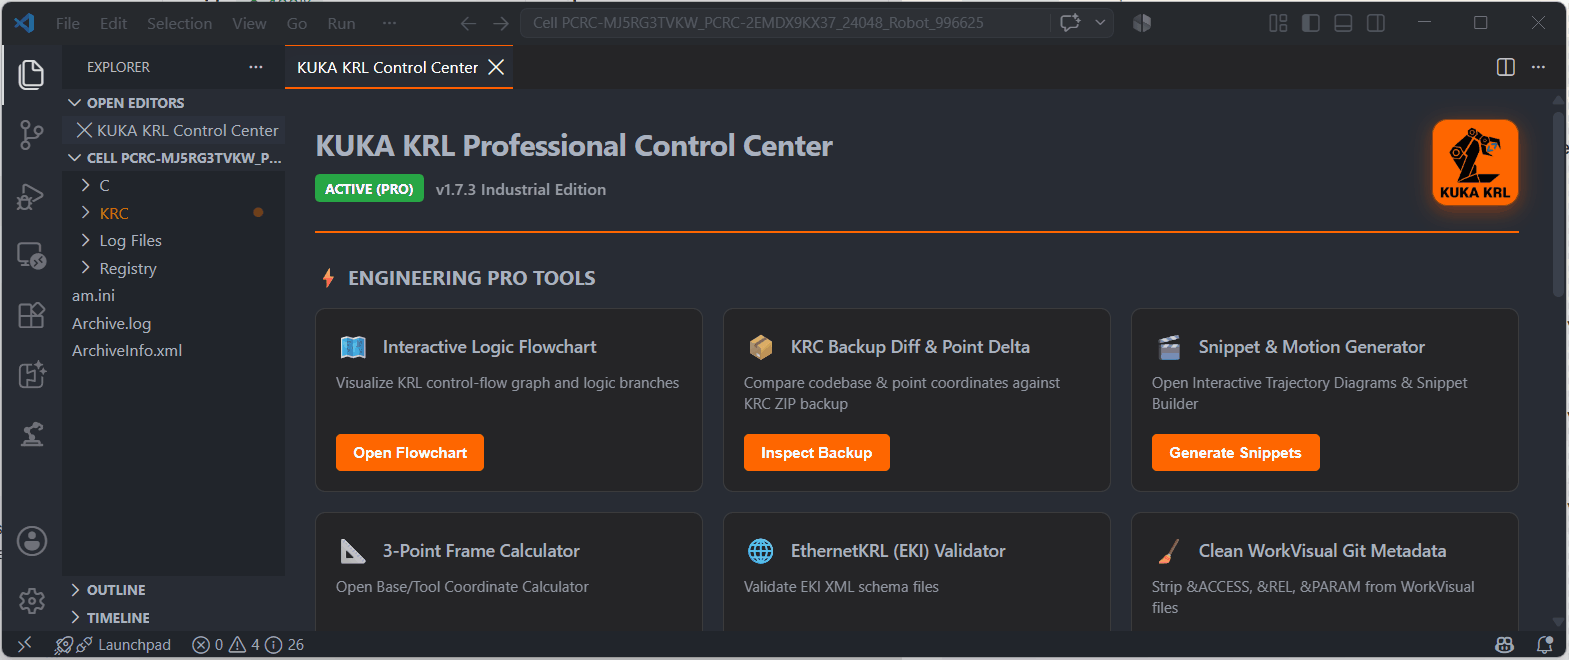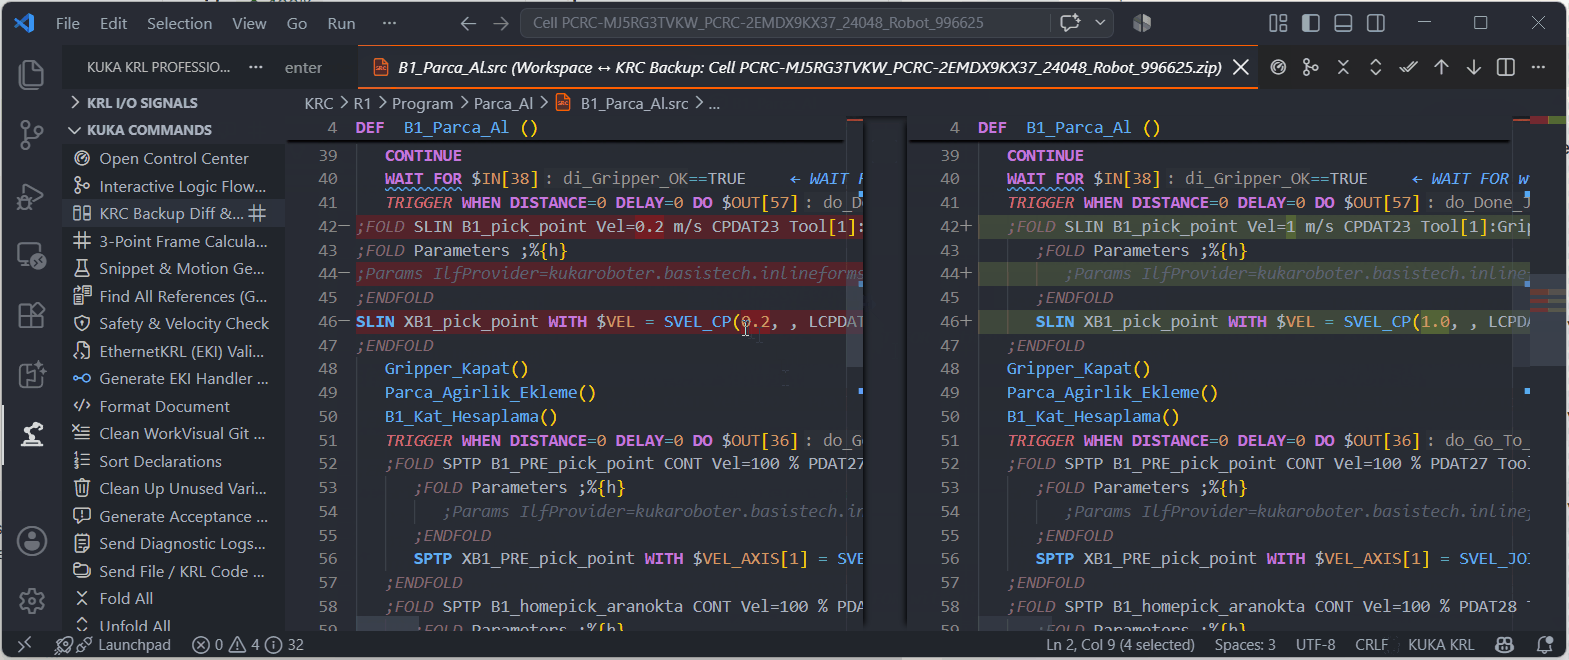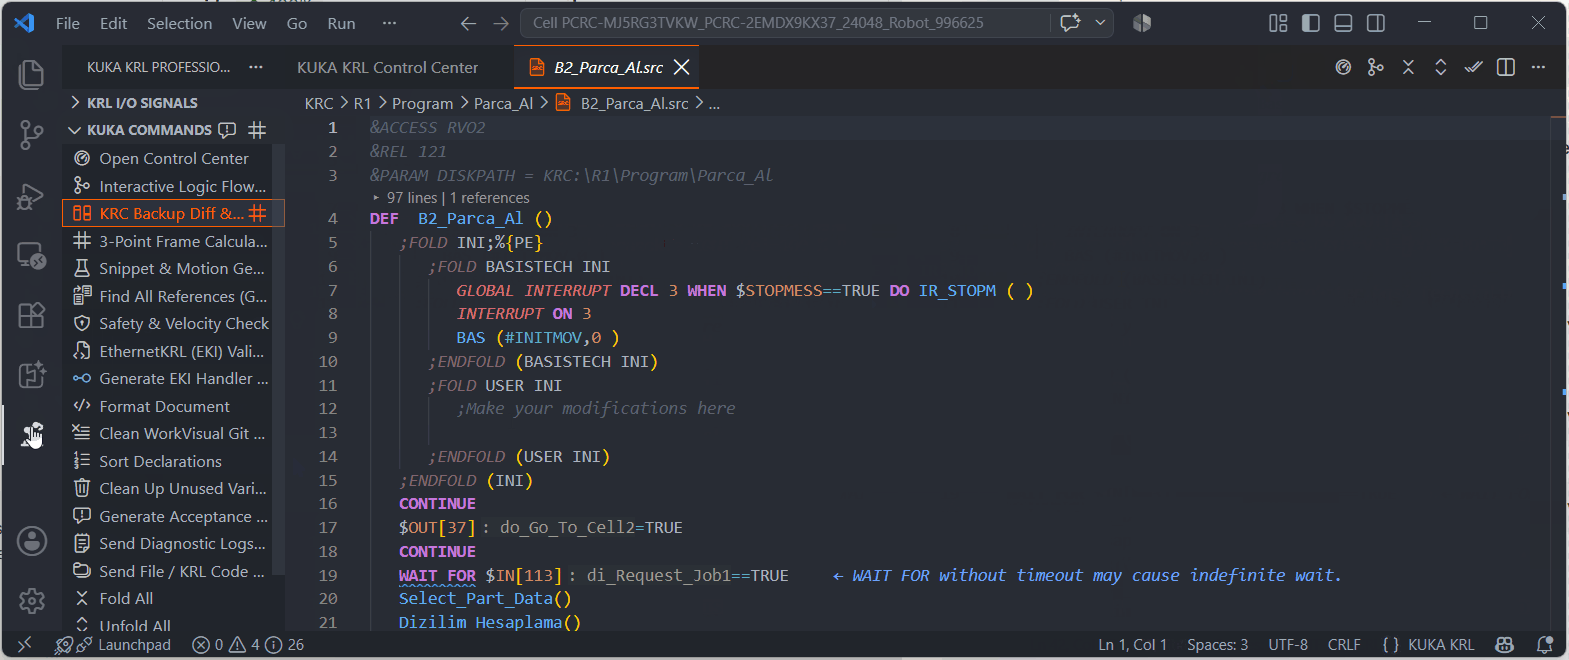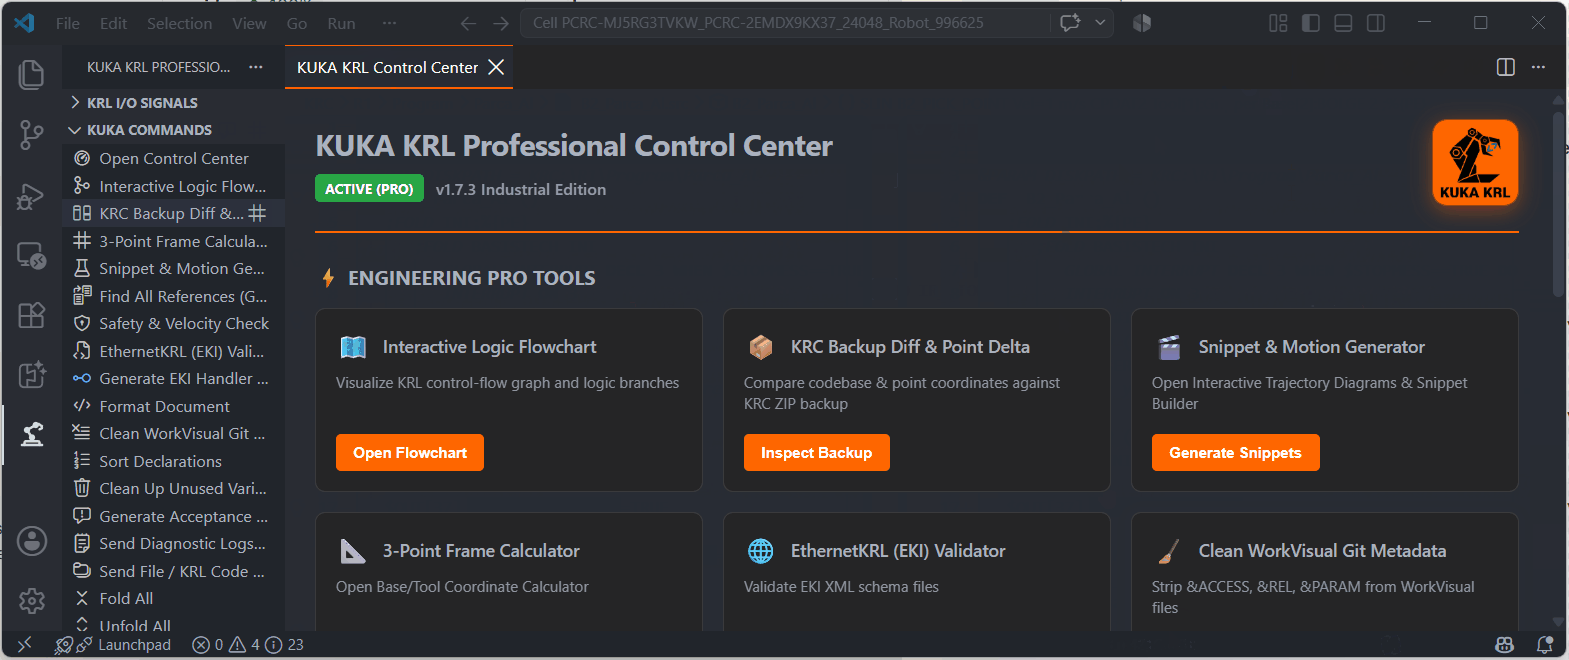
18. KRC Fleet Backups & Point Delta Spatial Inspector (krl.compareKrcBackups)
Compare physical SmartPAD .zip backups directly without manual extraction. Calculates 6-axis spatial coordinate deltas ($\Delta X, \Delta Y, \Delta Z, \Delta A, \Delta B, \Delta C$) between teaching versions and highlights hazardous point shifts exceeding safety tolerances.
19. Interactive Motion Trajectory & Spline Block Generator (krl.insertMotionTrajectory, krl.insertSplineBlock)
Visual motion sequence builder for standard and modern KSS motions (PTP, LIN, CIRC, SPTP, SLIN, SCIRC, SPLINE Block) featuring dynamic SVG vector trajectory diagrams and $SGEAR_JERK profile validation.
20. Native Copilot-Style Persistent AI Diff Review (KrlReviewService)
Professional multi-file diff staging system for AI-assisted refactoring. Displays pending changes inline, in side-by-side diff viewers, and via status bar indicators. Allows reviewing, accepting, or rejecting changes per-file or per-hunk (krl.review.acceptFile, krl.review.rejectFile, krl.review.acceptHunk, krl.review.rejectHunk).
21. KSS Spline Kinematic Separation & Modern Spline Converter (krl.convertLegacyToSpline)
Strict architectural segregation between standard legacy movements (PTP, LIN, CIRC) and modern Spline kinematics (SPTP, SLIN, SCIRC). Prevents illegal parameter mixing (e.g. $APO.CDIS inside Spline blocks) and provides 1-click batch conversion of legacy motion blocks into optimized Spline segments.
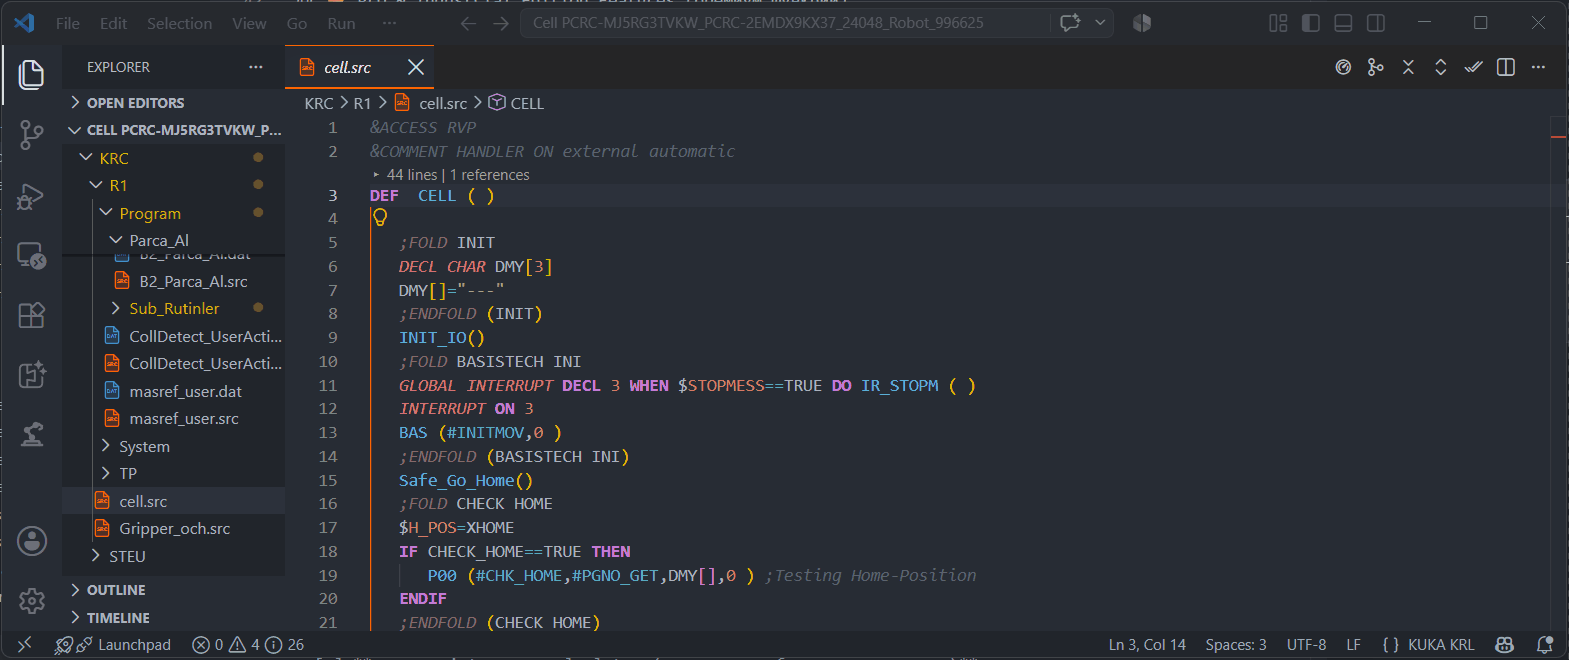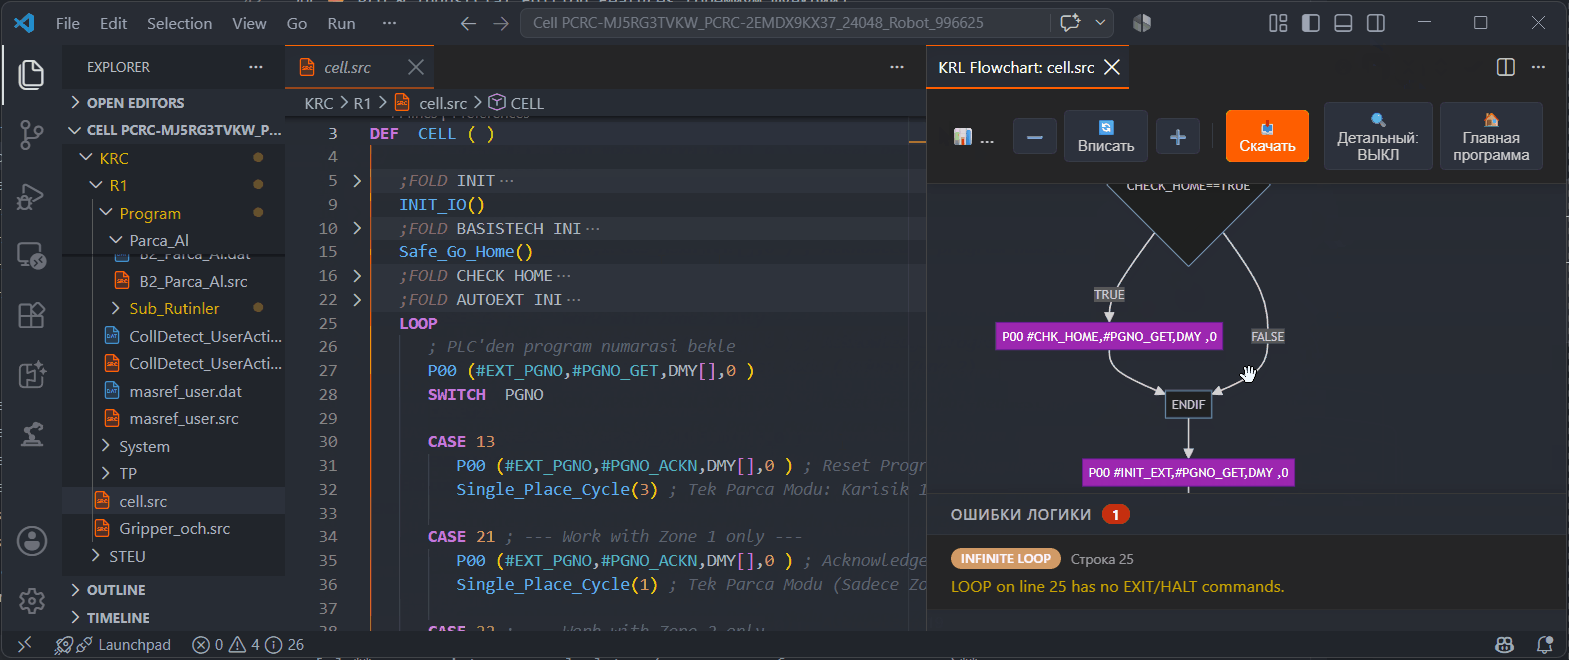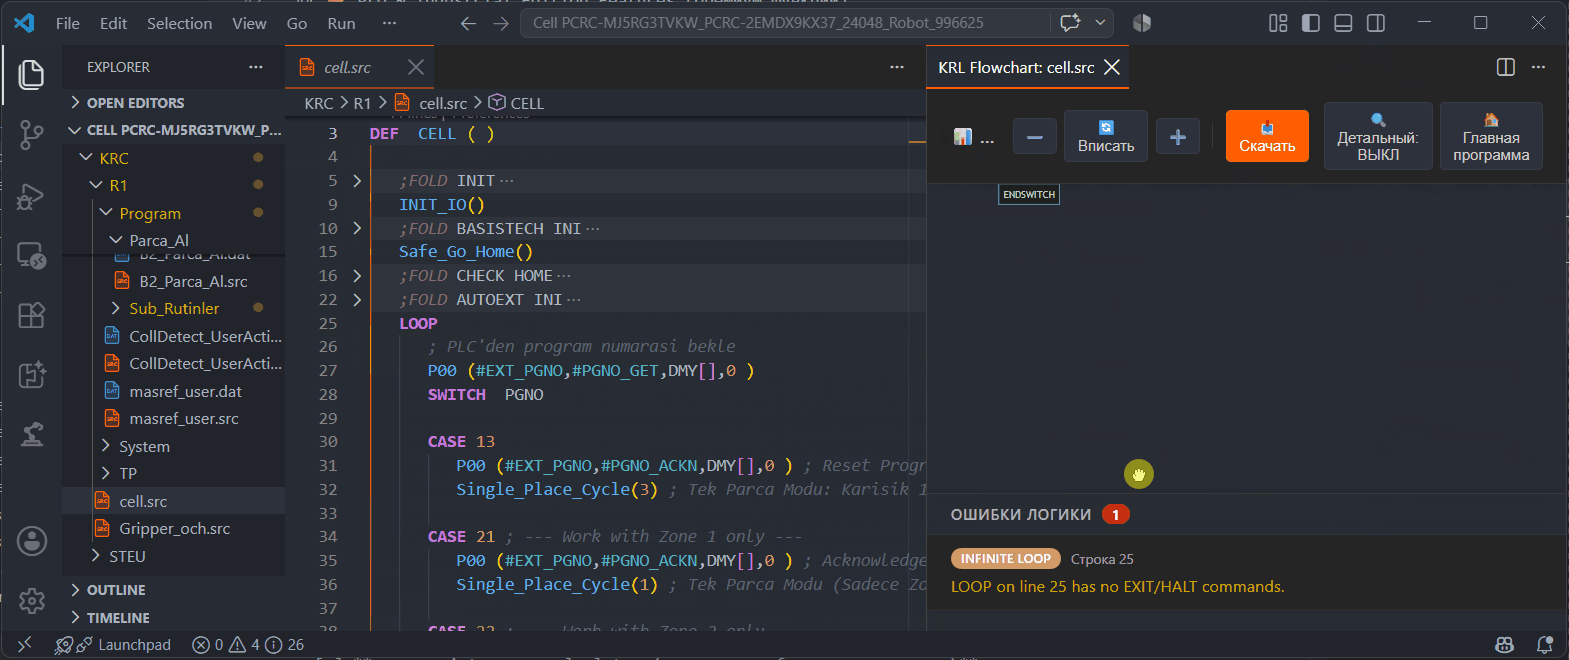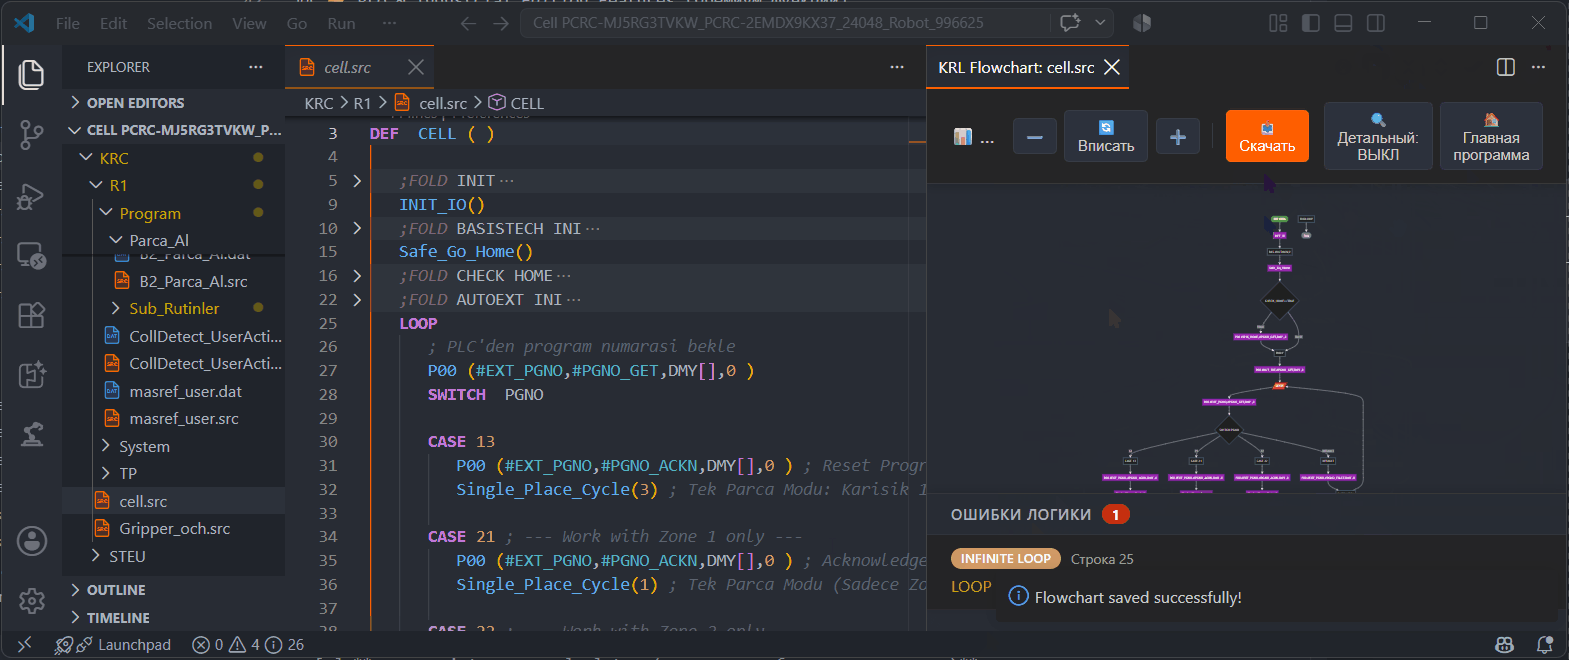
22. Interactive Flowchart Viewer & Control Flow Graph (krl.showFlowchart)
Transforms intricate .src subroutine logic into interactive Mermaid SVG diagrams in real time. Features bidirectional navigation (clicking graph nodes jumps directly to the source line) and 1-click vector SVG export for customer documentation and acceptance reports.

23. EthernetKRL (EKI) Suite & Telegram Generator (krl.generateEkiTelegram)
Validates EKI XML schemas and channel descriptors, tests socket telegram buffers, and auto-generates complete KRL network send/receive routines.
24. Industrial Safety & ISO 13849 Compliance Inspector (krl.runSafetyCheck)
Automated diagnostic inspector flagging uninitialized $TOOL/$BASE, missing BAS(#INITMOV, 0), unmonitored WAIT FOR deadlocks, array index overruns (TOOL_DATA[16]), dual-channel $SAFEIN discrepancies, and invisible Cyrillic look-alike characters.
25. EVT Binary Event Log Decoder (krl.viewEvtLog)
High-speed zero-dependency decoder for KSS .evt binary diagnostic event archives. Decodes timestamps, event IDs, severity levels, and module origins into an interactive, filterable tabular log viewer.
26. Signal Matrix & I/O Spreadsheet Viewer (krl.showIoMatrix)
Interactive cross-reference table mapping all $IN, $OUT, $ANIN, and $ANOUT signals across the workspace. Search, filter by comment, detect unmapped or duplicated fieldbus channels, and export to CSV/Excel.
27. Trajectory Welding & Motion Statistics Profiler (krl.calculateMotionStats)
Comprehensive motion path profiler computing total cycle distances, motion segment counts, seam welding lengths, and velocity distributions across programs.
28. 3-Point Base/Tool Frame Calculator (krl.showCalculator)
3D frame transformation calculator (BASE_DATA[x] / TOOL_DATA[x]) computing Euler orientation angles (A, B, C) and transformation matrices from 3 physical touch points (Origin, X-axis, XY-plane).
29. AI-Supportive Domain Context Tools (@kuka /get-io-matrix, @kuka /check-safety)
Native context providers and AST extraction tools enabling Google Antigravity IDE and GitHub Copilot to deeply understand KRL robot architectures, signal tables, and kinematics.
30. Industrial Acceptance Quality Report Generator (krl.generateQualityReport)
Generates comprehensive HTML and JSON code quality reports with safety scorecards, cyclomatic complexity metrics, and standard compliance audits for customer project sign-off.
31. 100% Adaptive Themes & Hexa-Locale Switcher
Factory-tuned dark, light, and high-contrast OLED themes with reactive SVG diagram rendering. Seamless 1-click switching across 6 industrial languages: English, German, Russian, Spanish, Italian, and Turkish.
32. Advanced KRL Kinematics & 6D Transformation Suite
Industrial offline trajectory and frame manipulation suite:
- 6D Trajectory Mirroring (
krl.mirrorTrajectory): Cartesian reflection across Planes X, Y, Z with automated Turn bit manipulation ($A_1..A_6$). - 6D Batch Point Transformation (
krl.batchShiftPoints): Geometric operator multiplication (:) for Tool offsets, Base offsets, and direct vector shifts. - Reverse Motion Path Trajectory (
krl.reverseTrajectory): Inverts sequence of motion targets while preserving circular trajectory segments and inline form folds. - Sequential Point Renumbering (
krl.renumberPoints): Synchronized batch renaming of points across.srcmotions, inline form folds, and companion.datsymbols (XP1,FP1,PPDAT1). - Tool & Base Coordinate Inspector (
krl.toolBaseOverview): Extracts, inspects, and exports all 64$TOOL_DATAand$BASE_DATAframes to CSV. - KFD User Tech Package Parser (
.kfd): Complete AST validation for custom Inline Form packages.
33. KUKA.Sim 4.10 & iiQWorks.Sim 1.3 Kinematic Safety Analyzers
Deep industrial simulation rules reverse-engineered from KUKA.Sim 4.10 & iiQWorks.Sim 1.3:
- Status (S) & Turn (T) Range Validator: Flags illegal kinematic Status ($S \notin 0..7$) and Turn bitmasks ($T \notin 0..63$).
- Context-Aware RESUME Analyzer: Flags illegal
RESUMEstatements outside interrupt handling subroutines. - FOR Loop STEP 0 Detector: Identifies infinite controller loop conditions where
FORloop step increment equals 0. - SUBMIT Interpreter Restrictions: Flags illegal synchronous robot motion commands inside background
$SPS.SUBtasks. - SYNC with SPLINE Sequence Guard: Verifies synchronous trigger statements inside spline blocks.
- Automotive Tech Package Protection: Shields KUKA.ServoGun (
%MKUKATPSERVOTECH), SpotTech, ArcTech, and GlueTech from corruption during refactoring.
34. Enterprise Fleet Reliability & Non-Destructive Code Verification
Verified across 9,804 real industrial plant modules (4.2M+ LoC across 17 robotics installations and 8 automotive/Tier-1 clients) with 0 line truncations, 0 block regressions, and 100% code preservation.
35. KRL Sichere automatische Reparatur (krl.fixAllSafeIssuesInFile)
Deterministische One-Click-Behebung von 7 Klassen syntaktischer und struktureller Fehler ohne Änderung der Bewegungskinematik:
- BOM- und Nicht-ASCII-Bereinigung: Entfernt UTF-8 BOM (
\xEF\xBB\xBF), typografische Anführungszeichen, Gedankenstriche und bereinigt Sonderzeichen zur Vermeidung von KSS-Compilerfehlern. - FOLD / ENDFOLD Desynchronisationsausgleich: Gleicht schließende
;ENDFOLD-Tags mit ihren;FOLD-Headern ab. - FOR Step-Zero-Schutz: Ersetzt fatale
STEP 0-Endlosschleifen durch sichereSTEP 1. - Fehlendes BRAKE vor RESUME: Ergänzt den erforderlichen
BRAKE-Befehl direkt vorRESUMEin Interrupt-Routinen (verhindert KSS01442). - Nutzlast-Commit ($LOAD): Fügt
BAS(#TOOL, currentTool)-Aufrufe nach$LOAD-Zuweisungen ein, um Motorüberlastungen zu verhindern. - Doppelte Überschleifparameter-Bereinigung: Normalisiert versehentlich duplizierte Blending-Token (
C_DIS,C_PTP). - Inline-Formular-Metadaten-Synchronisation: Synchronisiert XML-Parameter mit KRL-Anweisungen (
$OUT[...]), um fehlerhafte SmartPAD Touch-Up-Überschreibungen zu verhindern. - Rollback Guard & Monaco Diff: Automatischer Rückrollschutz bei Syntaxfehlern und visuelle Vorschau im Monaco Diff Editor vor dem Speichern.
NOTE
Bereinigung ungenutzter Variablen: Wird dediziert über das Werkzeug krl.cleanupUnusedVariables (Universal Backup & Unused Variable Purge Engine [PRO]) mit Schutz für $config.dat, sps.sub und EthernetKRL gesteuert.
36. Transparente KRC-Backup Live-Einbindung & 2-Wege-ZIP-Synchronisation (krl.mountBackupZipAsProject)
Öffnen von SmartPAD-Backups (Robot1.zip, KRCDiag_*.zip) direkt als Arbeitsbereich in VS Code ohne vorheriges Entpacken. Speichern (Ctrl+S) aktualisiert das ZIP-Archiv in <80ms direkt auf der Festplatte.
37. Dynamischer Bahnprofiler & Singularitätsprädiktor
Kinematische Vorab-Simulation und Singularitätsrisikoanalyse vor dem Laden auf den Roboter:
- Handachsen-Singularität (Wrist): Erkennung von Linearbewegungen nahe $A_5 \approx 0^\circ \pm 5^\circ$.
- Reichweitengrenzen: Warnung bei Überschreitung von 96% des maximalen Arbeitsbereichs.
- Taktzeitverlustanalyse: Berechnung von Verzögerungen durch Vorlaufstopps.
38. SCADA Live Bridge & Echtzeit-Steuerungsanbindung (krl.live.connect, krl.live.openDashboard) [PRO]
Direkte bidirektionale Telemetrie- und Diagnoseanbindung an physikalische KUKA KRC4/KRC5 und OfficePC-Steuerungen über CrossComm WCF, OPC UA oder EthernetKRL:
- Echtzeit-Koordinaten: Kartesische TCP-Positionen ($X, Y, Z, A, B, C$) und Achswinkel ($A_1..A_6$).
- Betriebsarten & Sicherheitskreise: Betriebsarten (T1, T2, AUT, EXT), Antriebsbereitschaft (
$PERI_RDY) und Not-Halt-Status ($ALARM_STOP). - Interpreter- und Zeigerverfolgung: Status von Submit (
$SPS) und Roboter-Interpreter ($PRO_STATE), Programmname ($PRO_NAME) und Zeilenzeiger ($PRO_IP). - Dynamischer Override: Anzeige und Anpassung des Programm-Overrides (
$OV_PRO). - Feldbus E/A-Diagnose: Live-Monitoring digitaler Ein-/Ausgänge (
$IN/$OUT1..4096) und Merker ($FLAG).
39. KSS Multi-Log Event-Inspektor & Zeitleiste (krl.openAllEventLogs) [PRO]
Zusammenführung aller Steuerungs- und Diagnoseprotokolle (KrcLog.evt, KSSLog.evt, etc.) in einer synchronisierten Zeitleiste mit automatischer mehrsprachiger KSS-Fehlercode-Übersetzung.
40. Klammer- und Array-tolerante Symbolauflösung
Robuste AST-Verarbeitung für komplexe KRL-Ausdrücke, Array-Indizierung und Strukturzugriffe (z. B. $OUT[12], $COUNT_I[1], LOAD_DATA[1].M).
41. Inline-Formular (ILF) Metadaten-Reparatur (krl.fixAllSafeIssuesInFile) [PRO]
Automatischer Abgleich und Reparatur von Parameter-Desynchronisationen zwischen KRL-Bewegungsbefehlen und internen XML-Metadatenkommentaren.
42. KSS 8.7.9 Kompatibilität & Robotermodell-Erweiterungen
Erweiterte Kinematikmodelle für KSS 8.7.9 (inkl. KR 50 R2500, GripperSpotTech) sowie Prüfung dynamischer Lastdaten (Masse, Schwerpunkt, Trägheitstensor).
43. WorkVisual (.wvs / .wvps) Bus-Topologie & KOP-Paket-Parser (krl.inspectWvsTopology) [PRO]
Direkte In-Memory-Prüfung binärer WorkVisual-Projekte ohne manuelle Archiv-Entpackung:
- KOP-Optionspakete: Auslesen installierter Technologiepakete (
KUKA.EthernetKRL,KUKA.SafeOperation,KUKA.GripperSpotTech,KUKA.Profinet), KSS-Laufzeitversion und Roboter-Kinematikprofile ausSolution.MetaData. - Feldbus-Topologie & E/A-Mapping: Analyse von EtherCAT-Kopplern/Scheiben (
EcatDiag_*.xml), Virtual I/O und Profinet-Bussen mit automatischer Adresszuordnung. - Signal-Export für SPS-CAD: Export der Signaltabellen (
$INund$OUT) nach Siemens TIA Portal XML/SDF, Beckhoff TwinCAT 3 GVL und EPLAN CSV.
44. Punkt-Autosynchronisation & Companion .DAT-Normalisierer (krl.syncPointsToDat) [PRO]
Deterministische Synchronisation räumlicher Punkte und Bewegungsparameter zwischen .src und .dat:
- AST-Bewegungsscan: Prüft alle Bewegungsbefehle (
PTP,LIN,CIRC,SPTP,SLIN,SCIRC) und Inline-Formulare (PDAT_ACT,FDAT_ACT,LDAT_ACT). - Erstellung fehlender .DAT-Dateien: Generiert automatisch eine gültige
DEFDAT <MODULE> PUBLICModulstruktur. - Injektion fehlender Punkte: Fügt Deklarationen (
DECL E6POS,DECL FDAT,DECL PDAT,DECL LDAT) in einen sauberen;FOLD Auto-Synchronized PointsBereich vorENDDATein, ohne geteachte Koordinaten zu verändern.
45. KUKA.Sim & Visual Components (.vcmx) Simulations-Suite [PRO]
Analyse und Postprocessing von 3D-Simulationsmodellen (krl.inspectVcmxLayout, krl.validateVcmxSimulation, krl.exportVcmxToKrl):
- VCMX-Zellen-Inspektor: Zweischichtiger
layout.rsc-Parser zum Auslesen von Roboterkinematik, Signalen und Prozessroutinen ohne Start schwerer Simulationssoftware. - Simulations-Deadlock & Race-Validator: Erkennt und repariert 4 kritische Simulationsfehler (
VCMX001Flankendeadlocks,VCMX002Timeout-Fehler,VCMX003Variablenlecks,VCMX004verlorene Signalreferenzen) mit automatischer.bk1/.bk2-Sicherung. - VCMX-zu-KRL Postprozessor: Wandelt Simulationsschritte (
LinMotion,PtpMotion,SetSignal,WaitSignal) direkt in synchronisierte KRL.src+.datModule um.
46. KUKA.RobotSensorInterface (RSI) 4ms Echtzeit-Suite [PRO]
Entwicklung und Validierung von Echtzeit-Sensorkorrekturschleifen (krl.validateRsiXml, krl.generateRsiCode):
- RSI XML-Schemavalidator: Überprüfung der
SensorInterface/*.xml-Struktur, Socket-Parameter, Datentypen undINDX-Kontinuität. - 4ms / 12ms Echtzeit-Treiber-Generator: Generierung von
#IPO_FAST(4ms / 250Hz) und#IPO(12ms / 83Hz) KRL-Korrekturschleifen für kartesische Korrekturen (#POSCORR) und ROS 2 Achssteuerung (#AXISCORR). - Integrierte RSI-Systembibliothek: Signaturhilfen und Typdefinitionen für
RSI_CREATE,RSI_ON,RSI_MOVECORR,RSI_OFF,RSI_DELETE.
47. CAM CNC G-Code & SVG-Vektor-Importer (krl.importGcodeToKrl) [PRO]
Konvertiert CAD/CAM-Werkzeugbahnen und 2D-Vektoren in produktiven KRL-Code:
- ISO G-Code-Konvertierung:
G0$\rightarrow$PTP/SPTP,G1$\rightarrow$LIN/SLIN,G2/G3$\rightarrow$CIRC/SCIRCmit exakter 3D-Bogenmittelpunktberechnung. Vorschubumrechnung in$VEL.CPund M-Code-Mapping (M3,M5) auf$OUT[...]. - SVG-Vektor-Import: Parsing von
<path>,<polyline>,<polygon>,<circle>mit Bezier-Approximation und automatischen SicherheitsebenenZ_Safeund SchnittebenenZ_Work.
48. 9-Punkt Hand-Auge-Kamerakalibrierung & SPS-Tag-Export [PRO]
- Hand-Auge-Kalibrierpyramide (
krl.generateVisionCalibration): Look-At Rotationsmatrix-Berechnung für KUKA Euler-Winkel ($A, B, C$) beiEye-in-HandundEye-to-HandKamerasystemen mit Vorgriff-Approximation. - SPS-Feldbus-Tag-Export (
krl.exportPlcTags): Auslesen vonSIGNAL,$IN,$OUTDeklarationen mit IEC 61131-3 Adressierung (%I0.0,%Q0.0) nach TIA Portal XML/SDF, TwinCAT 3 GVL und EPLAN CSV.
49. Integrierter Model Context Protocol (MCP) KI-Server [PRO]
Lokale sichere KI-Schnittstelle (127.0.0.1):
- Verbindung zu Cursor, Antigravity, Claude Code und Windsurf: Bereitstellung von Echtzeit-Telemetrie (
krl_live_telemetry), statischer Code-Diagnose (krl_workspace_diagnostics), automatischer Reparatur (krl_safe_auto_repair) und Spezifikationen für 957+ KSS-Systemvariablen. - 1-Klick-Konfigurations-Export: Befehl
krl.copyMcpConfigzum einfachen Einfügen in Claude Desktop und Cursor.
50. Enterprise Air-Gap Offline-Lizenzierung (.lic Dateiaustausch) [PRO]
- Hardware-ID-Anforderung exportieren (
krl.exportHardwareIdFile): Erzeugt eine signierteliskin-hardware-id.lic-Datei für den USB-Transfer in isolierten Produktionsnetzen. - Signierte Lizenz importieren (
krl.importOfflineLicenseFile): Prüft die asymmetrische Ed25519-Signatur ausliskin-krl-license.licsofort offline und schaltet den PRO-Modus dauerhaft frei.